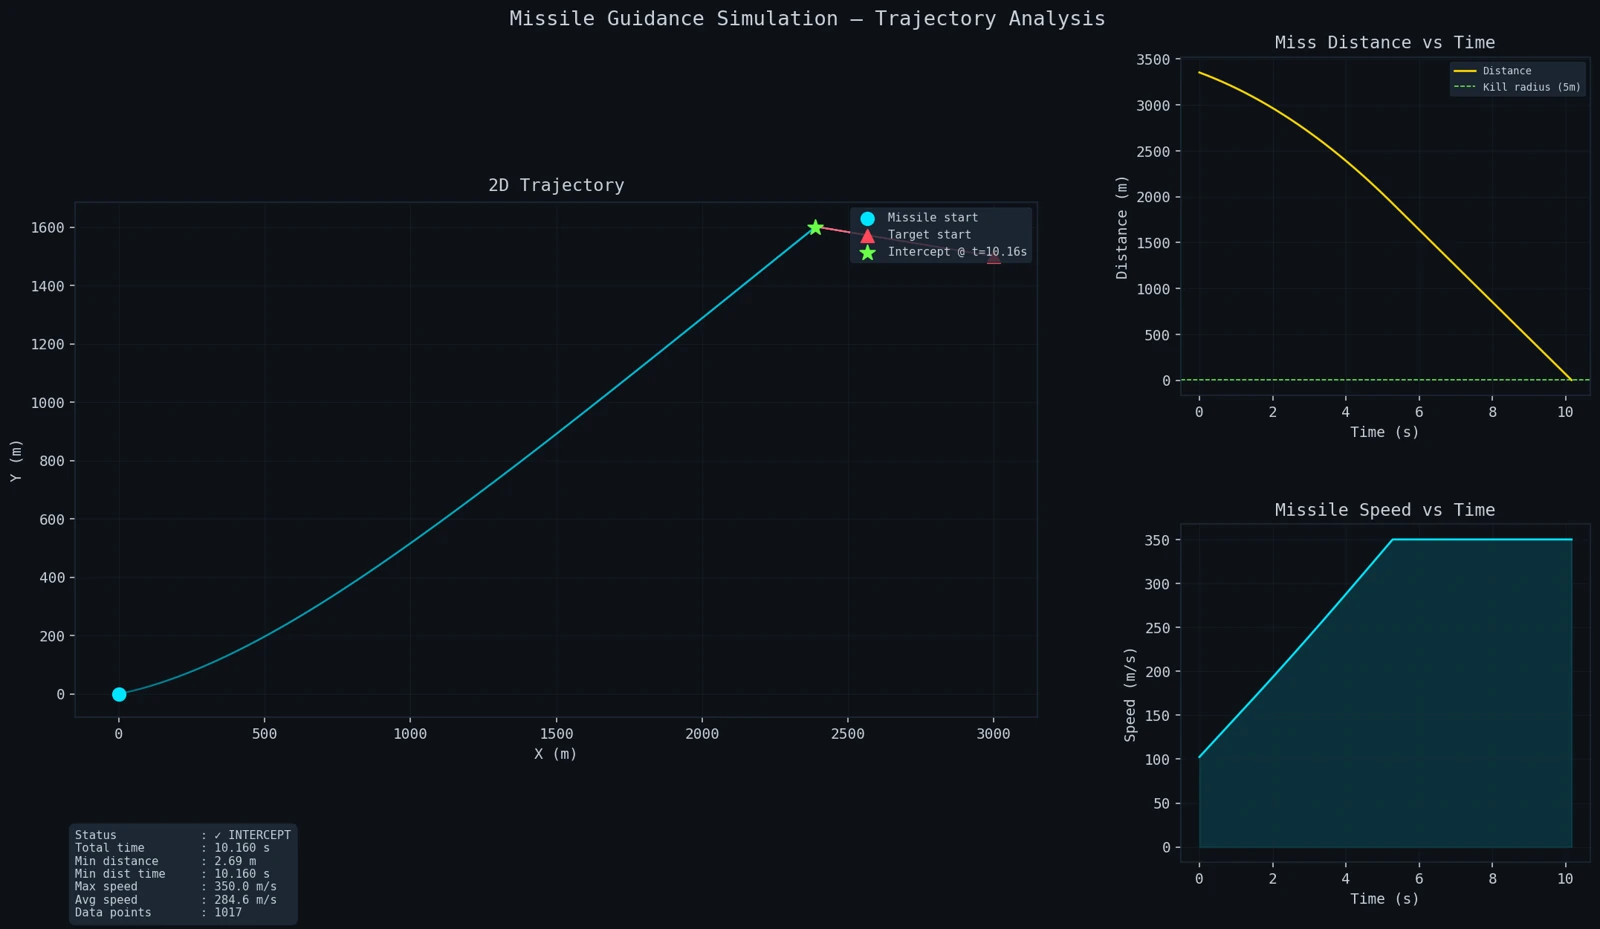
Repository figure: Pitambar Lamichhane (pirmber) · Repository image · Resized and converted to WebP.
Created by Pitambar Lamichhane.
Exploring motion and feedback control
Brahmastra studies two classical guidance approaches in a two-dimensional simulation: Proportional Navigation and PID heading correction. Its C99 engine models motion, drag and configurable target behavior, including linear, sinusoidal and evasive trajectories.
A terminal interface configures runs, while CSV logs and a Python visualization layer support trajectory analysis and animation. The project provides an educational setting for exploring physics, numerical integration and control systems.
The cover is the repository’s trajectory-analysis figure from a sample run.
Contributors
- Pitambar Lamichhane