Repository figure: Pitambar Lamichhane (pirmber) · Repository image · Resized and converted to WebP.
Created by Pitambar Lamichhane.
Comparing search strategies on the same terrain
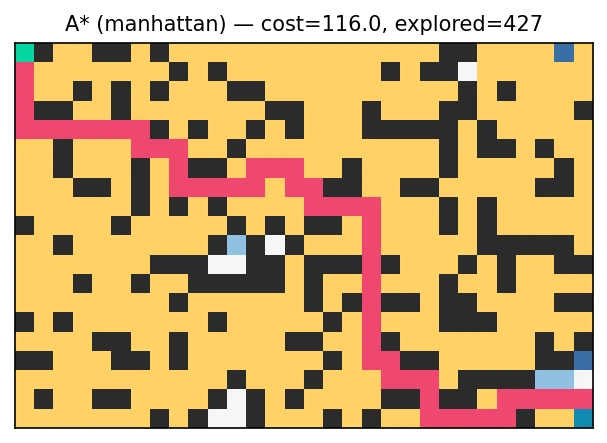
VECTOR implements five search strategies from scratch and evaluates them against shared grid environments with seeded obstacles and optional weighted terrain. Results record path cost, explored nodes, frontier size, success and execution time in CSV files.
Static plots and animations illustrate the trade-offs between search cost and path quality. An optional dynamic layer detects blocked paths and replans from scratch when obstacles change. The experiments include Manhattan and Euclidean heuristics for A* on four-connected grids.
The cover shows an A* search visualization published in the repository; benchmark outcomes depend on the environment and machine used.
Contributors
- Pitambar Lamichhane