Learning to navigate
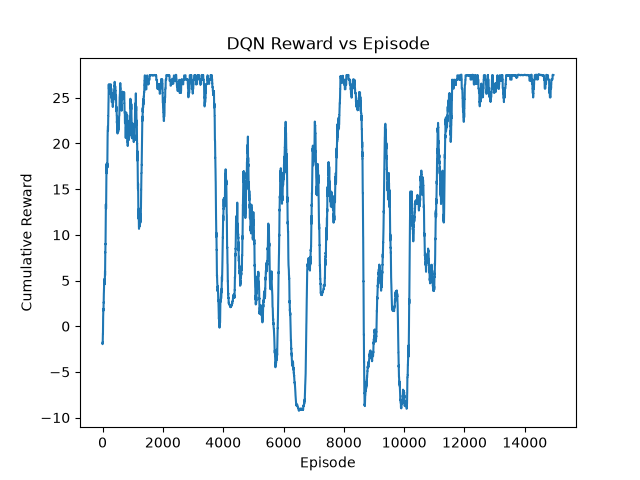
Spatial_Preception compares behavioral cloning with Deep Q-Networks for autonomous obstacle avoidance in simulated environments.
The project includes expert demonstration data, custom simulations, training notebooks, and a Double-DQN implementation. It explores how supervised imitation and reinforcement learning affect navigation and decision-making.
Contributors
- Prashanna Tiwari