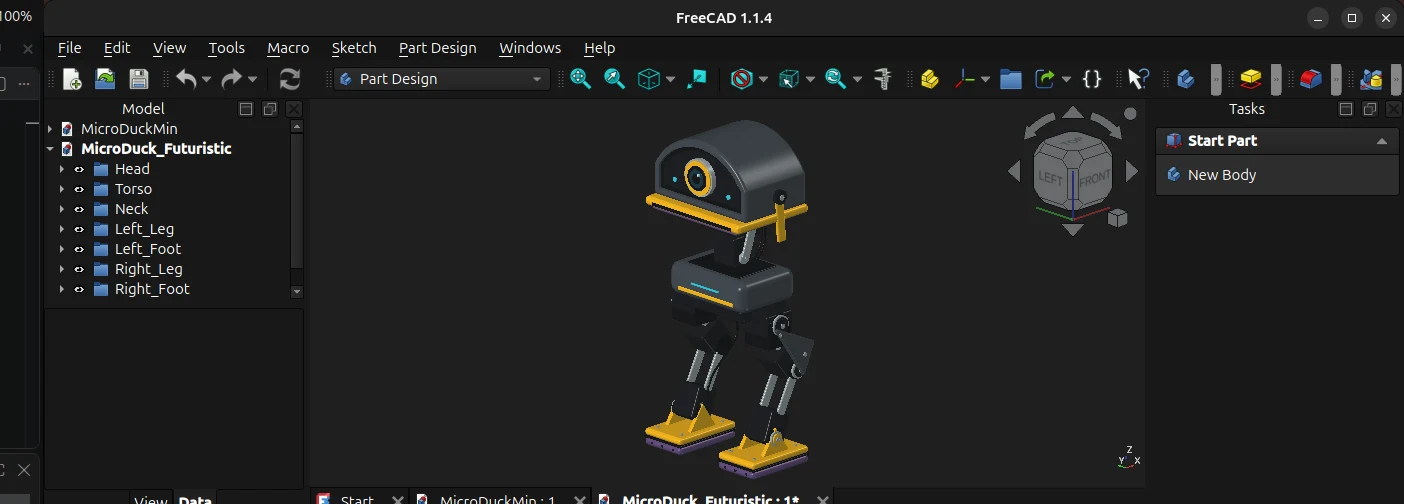
FreeCAD concept screenshot: Prashanna Tiwari · Author-provided image; CAD assets have separate terms · Resized and converted to WebP.
Created by Prashanna Tiwari.
Connecting robot design and learned control
Microduck combines a FreeCAD appearance concept with a six-joint biped simulation and Proximal Policy Optimization training. The repository provides robot configurations, bounded training runs, evaluation suites, policy artifacts and a keyboard-controlled MuJoCo viewer.
The initial study compares four conditions across three seeds, with 12 policies trained for 1,536,000 transitions each. The repository reports that full moving-command acceptance was not reached and identifies heading control as a failure. A separate futuristic model uses CAD-based surfaces and proportions, with its own training and playback setup.
Physical parameters remain provisional. These are simulation experiments; reliable walking, hardware transfer and fabrication readiness have not been established.
Licensing
The scoped MIT License covers original software in src/, tests/ and scripts/ and associated software documentation. Supplied robot/CAD assets and third-party dependencies are excluded; consult THIRD_PARTY.md. The cover is the repository’s FreeCAD concept screenshot.
Contributors
- Prashanna Tiwari