Gallery
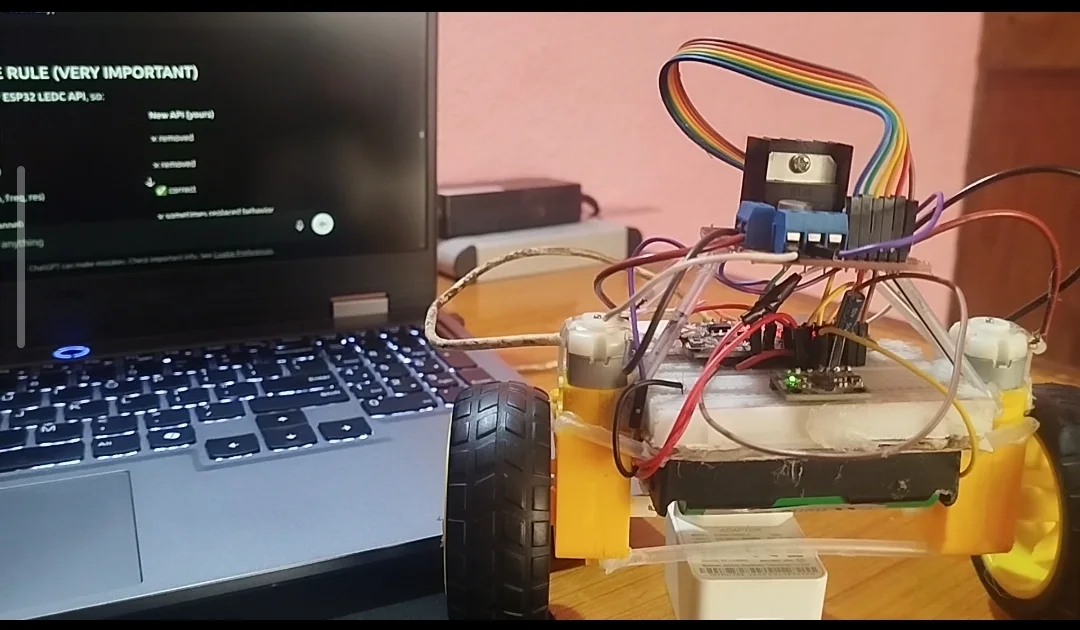
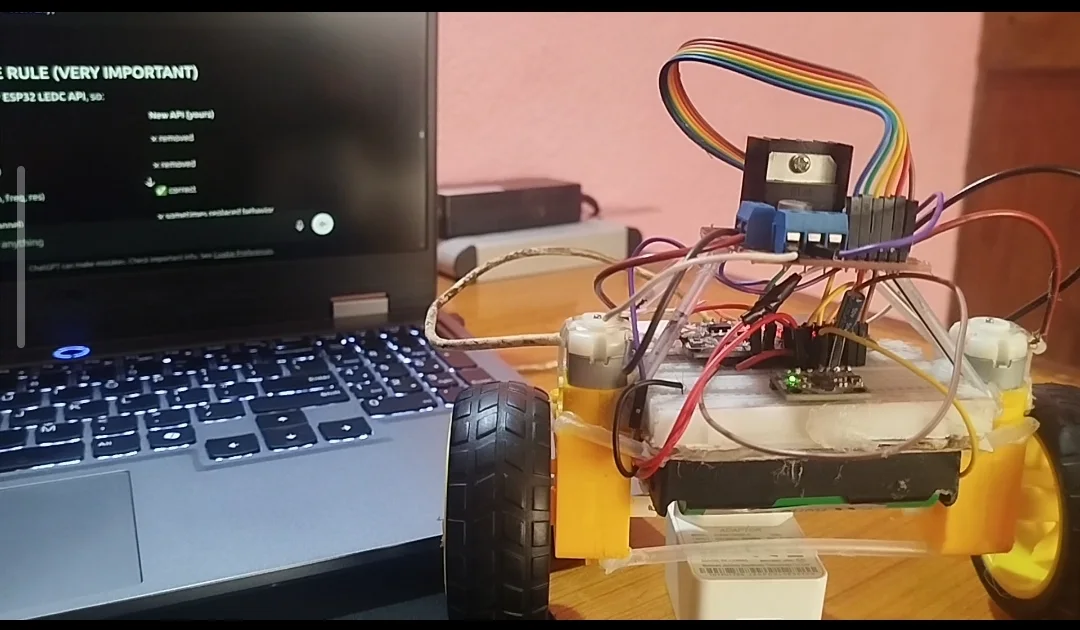
I am building a self-balancing robot using the MPU6050 sensor to measure tilt and angular motion. The robot uses a PID controller to maintain its upright position by adjusting the motors in real time. The project involves sensor calibration, motor control, and feedback systems. My goal is to achieve stable balancing and understand the practical challenges of inverted-pendulum control.
Contributors
- Prashanna Tiwari